We have developed autonomous map navigation and obstacle avoidance

November 13, 2019 | Development
Thanks to our algorithm, the Husky A200 robotic platform by the Canadian company Clearpath Robotics moves autonomously along a selected route, while bypassing static and dynamic obstacles. The environment must first be mapped by a teleoperator before autonomous driving.
Extension of the algorithm by a map
RoboTech Vision has developed an algorithm that allows the robot to segment the path or rows of vines. However, the company decided to extend the so-called reactive navigation, when the robot responds to conditions in the environment with its sensor system, to include mapping data to increase safety. It is a navigation using a local map of the environment which, with the necessary sensor equipment, can be deployed to another device.
Therefore, the environment in which the robot is to move autonomously must be mapped in a teleoperator mode first, when the robot uses sensors to scan the environment. The robot then navigates to the specified waypoint, mainly according to the map. But it still perceives its surroundings and in case of incorrect location on the map or at the risk of collision with an obstacle. In that case it starts to follow reactive navigation, replans the route, bypasses the obstacle and continues according to the map to the specified destination.
Author of the post
Related articles
Husky A200 robot recognizes and autonomously follows objects
Androver II robot drove 1,5 kilometers autonomously using our algorithm
Androver II robot moves autonomously between vineyard rows
Categories
LATEST POSTS
Androver II visited a nuclear power plant
Androver II visited a nuclear power plantDecember 14, 2018 | Presentation The RoboTech Vision team participated in the evaluation of the Mission Mars II competition at the Nuclear Power Plant in Mochovce. Together with astrobiologist Dr. Michaela...
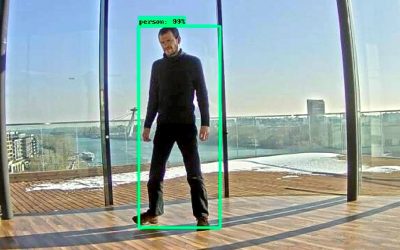
Husky A200 robot recognizes and autonomously follows objects
Husky A200 robot recognizes and autonomously follows objectsDecember 7, 2018 | Development After the Husky A200 robot was able to autonomously follow the mark, RoboTech Vision managed to improve the algorithm so that the robot would track even...
Androver II participated in the Talks conference
Androver II participated in the Talks conferenceNovember 24, 2018 | Presentation The team of RoboTech Vision presented its robot Androver II at the Talks conference in Bratislava in front of important people from diplomacy and various fields of...